Blog

Notes from the edge

Engineering deep-dives, deployment stories, and honest hardware comparisons from the team building the depth sensors, capture rigs, and SDK.

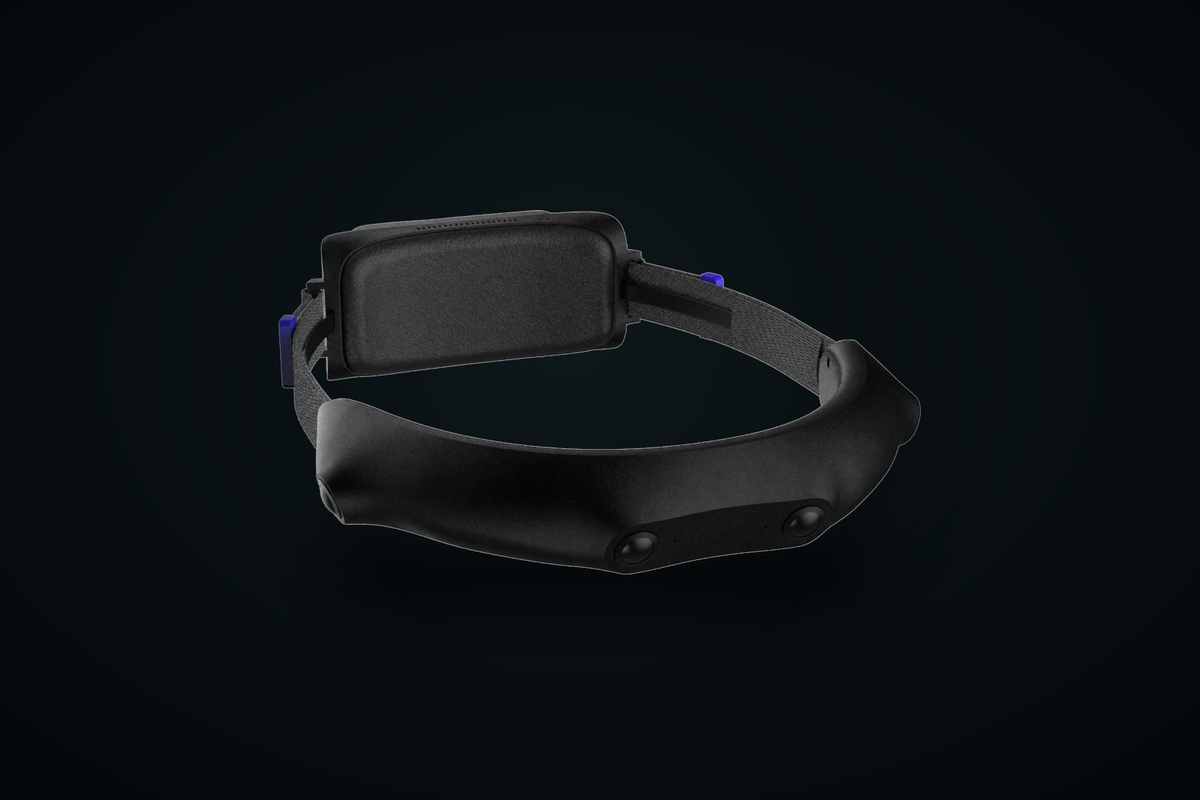
Wego4 quad-camera egocentric capture rig on a dark studio background

How to choose egocentric data collection hardware for robot training

What actually matters when buying a first-person data capture rig for physical-AI datasets: hardware time sync vs software alignment, global vs rolling shutter, camera coverage, and battery endurance — with a worked comparison.

Read article →
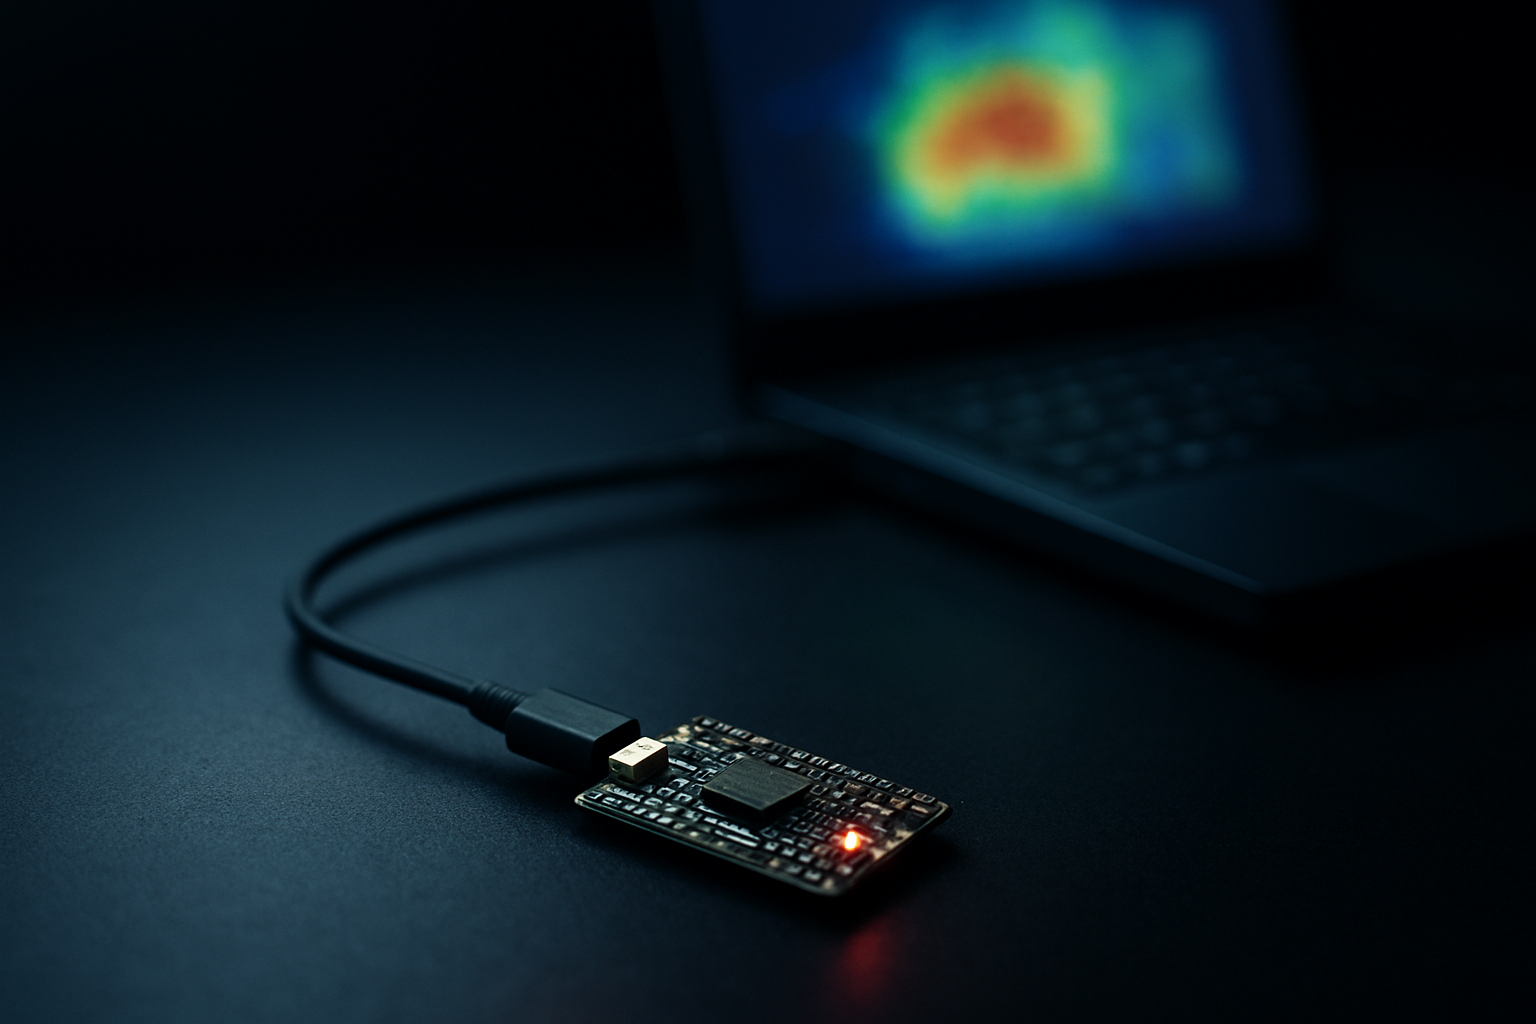
A bare ToF sensor board on a USB cable beside a laptop showing a depth heatmap

Bringing up a ToF camera board: why UVC enumerates but sends zero frames

A field log of bringing up an OPNOUS/SigmaStar ToF board over USB. UVC enumerates, every format negotiates, and not one frame arrives — because the sensor pipeline needs a vendor Extension Unit command first. How we found it and got depth out.

Read article →
Depth-based AI agent pipeline turning camera frames into safety alerts

From camera to agent: a forklift-safety system in 30 minutes

A step-by-step build of a warehouse forklift-safety system from one depth LiDAR: person and forklift detection from pure depth, convergence events, Slack alerts, and auto-generated incident reports — the full pipeline, in about ten lines.

Read article →
A robot perceiving a room as a structured point cloud

Why Physical AI starts with spatial intelligence

Language models learned from the internet's text; robots have to read rooms. The case for depth as the first-class citizen of embodied AI — and why a small depth array can beat a 4K camera at navigation for a hundredth of the compute.

Read article →
A staged over-the-air update rolling across a fleet of cameras in waves

Staged OTA for 100 cameras without a single bricked device

How a camera-fleet runtime rolls out firmware in waves with automatic health verification and rollback, an A/B partition scheme that has no unbootable state, and 3,000+ device-updates with zero truck rolls.

Read article →
Indirect ToF phase wave compared with direct ToF photon pulses

iToF vs dToF: choosing the right depth technology

Indirect vs direct time-of-flight, compared honestly across resolution, sunlight, integration, and power — with a rule of thumb for interaction, navigation, drop-in simplicity, and battery products.

Read article →
Header illustration for 'Teleoperation vs. Egocentric Capture: A Cost-Per-Demonstration Analysis for Imitation Learning'

Teleoperation vs. Egocentric Capture: A Cost-Per-Demonstration Analysis for Imitation Learning

Compare teleoperation rigs and head-worn Wego2/Wego4 capture for imitation learning. Analyze setup, training, and throughput to find the winning method.

Read article →