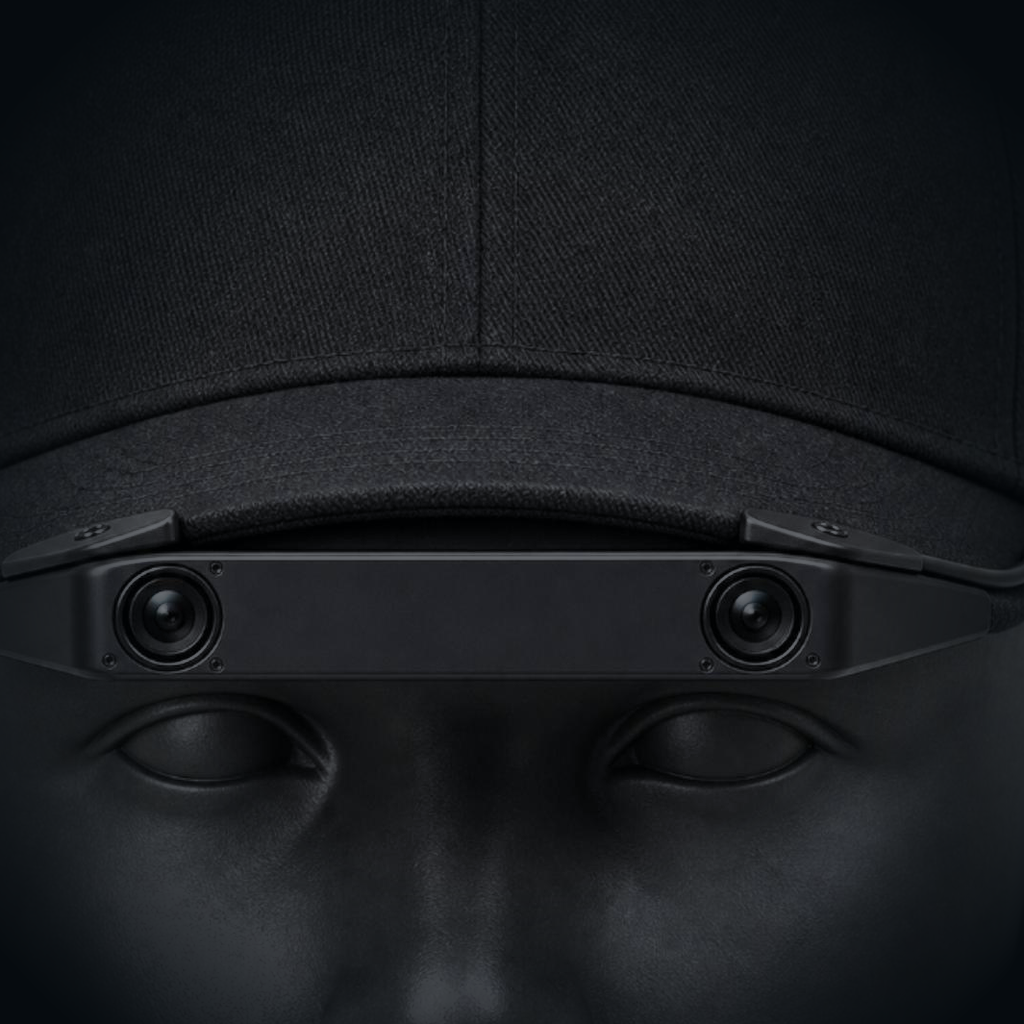
Wego2
An entry-level egocentric capture terminal for physical-AI datasets. Two global-shutter cameras cover the forward work zone, a hardware-timestamped IMU rides along with every frame, and a hot-swap battery keeps a shift running — cheap enough to hand out by the dozen.
5 in stock — ships now
- 2 × SC233HGS global-shutter cameras, 1920 × 1200 (2 MP), 155° (V) × 109° (H)
- ICM-42688 6-axis IMU at 200 / 500 Hz, hardware-timestamped against video — no software drift
- Rockchip RV1103B with 0.5 TOPS for on-device capture control
- 5600 mAh hot-swap main battery + 500 mAh UPS backup — change packs without ending the session
- MP4 / H.265 plus per-image timestamps, IMU stream, audio and calibration parameters
First 5 units ship from stock; beyond that, built to order in 30–60 days · 2-year warranty · Pairs with VisionLibra Data Services
Technical specs
| Basic | |
|---|---|
| Role | Entry-level egocentric capture terminal — first-person video, IMU, audio, offline trajectory |
| Form Factor | Glasses-style / cap-brim front module |
| Capture Coverage | Two global-shutter cameras across the forward work zone |
| Typical Use | Home, factory and field task capture; multi-unit batch collection |
| Cameras | |
| Sensor | 2 × SC233HGS, global shutter |
| Resolution | 1920 × 1200 (2 MP) per camera |
| Field of View | 155° (V) × 109° (H) |
| Compute | |
| SoC | Rockchip RV1103B |
| NPU | 0.5 TOPS |
| CPU | Single-core Arm Cortex-A7 + RISC-V |
| Motion & Sync | |
| IMU | ICM-42688, 6-axis |
| IMU Rate | 200 Hz / 500 Hz |
| Time Alignment | Hardware timestamps shared between IMU and video |
| Power | |
| Main Battery | 5600 mAh, hot-swappable |
| Backup | 500 mAh UPS — bridges the swap |
| Connectivity & Storage | |
| Wireless | Wi-Fi 6 dual-band + BLE 5.4 |
| Storage | microSD (TF) card |
| Data Output | |
| Video | MP4 / H.265 |
| Metadata | Per-image timestamps, IMU timestamps, audio, calibration parameters |
| Software | Linux, open data interface, offline trajectory-solving tools |
Built for
Household Tasks
Capture everyday manipulation at home — the long tail robots still fail at.
Factory & Field
Record operator procedure on the line, at volume, without instrumenting the plant.
Dataset Scale-Out
Cheap enough to run dozens in parallel when you need hours, not minutes.
Imitation Learning
First-person video plus synchronised motion — the input format policies train on.
Low-cost, fleet-deployable first-person capture
Capturing a dataset rather than building one device? Our data services team runs collection, annotation and evaluation on top of this hardware.