Hardware for every scale of physical AI
Depth sensors, egocentric capture rigs and edge compute — one platform. Every VisionLibra device runs the same SpatialAI SDK, deploys the same models, and reports to the same fleet dashboard.

Spatial Mini
A 4.4 × 2.4 mm distance sensor with 5 m range — presence and gesture intelligence for any product.

Spatial Home
An all-in-one 3D ToF solution — up to 100 × 100 depth with on-module processing, made for IoT and smart home.

Spatial Vision
A compact 3D depth camera that sees people, hands, and spaces — built for interaction at human scale.
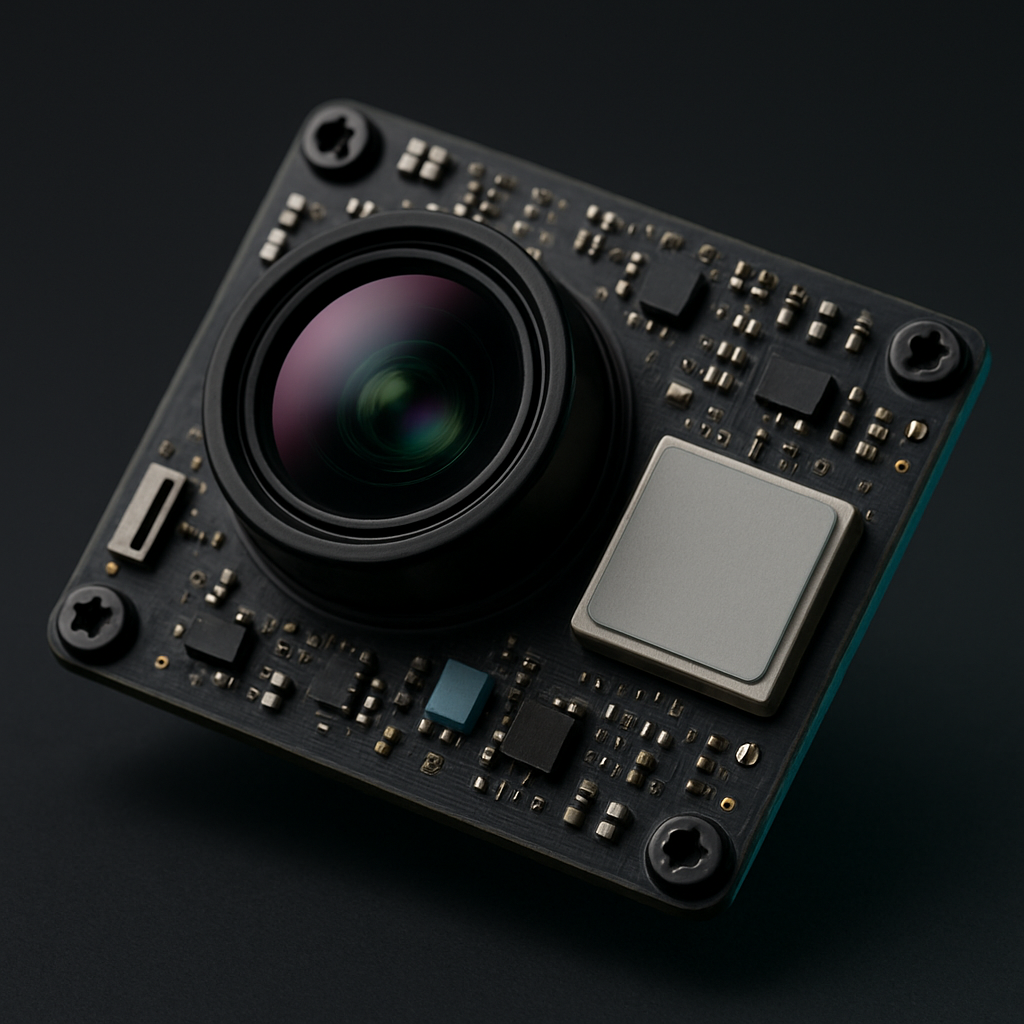
Spatial Robot
Miniature 8 m SPAD LiDAR array for machines that move — sunlight-tolerant depth for AMRs and drones.
Which sensor fits your build?
| Spatial Mini | Spatial Home | Spatial Vision | Spatial Robot | |
|---|---|---|---|---|
| Technology | 1D ToF | All-in-one 3D ToF | iToF depth camera | SPAD dToF array |
| Resolution | Single zone | Up to 100 × 100 | 320 × 240 | 40 × 30 |
| Range | 0.02 – 5 m | 0.2 – 2.5 m | 0.2 – 2 m | 0.2 – 8 m |
| Field of View | 25° | 60° × 60° | 71.8° × 56.6° | 60° × 45° |
| Frame Rate | Up to 50 Hz | Up to 20 fps | 10 – 30 fps | 10 fps |
| Outdoor | Indoor | Indoor | Indoor | Sunlight-tolerant |
| Best for | Locks, IoT, presence | Smart home, IoT hubs | Retail, AR, gesture | AMR, drones, SLAM |
| Price | $9 | $39 | $59 | $99 |
Wego — egocentric rigs for physical-AI datasets
Robots learn from demonstration, and demonstration has to be recorded first. The Wego rigs capture first-person video with a hardware-timestamped IMU riding on every frame — the format imitation-learning pipelines actually consume.
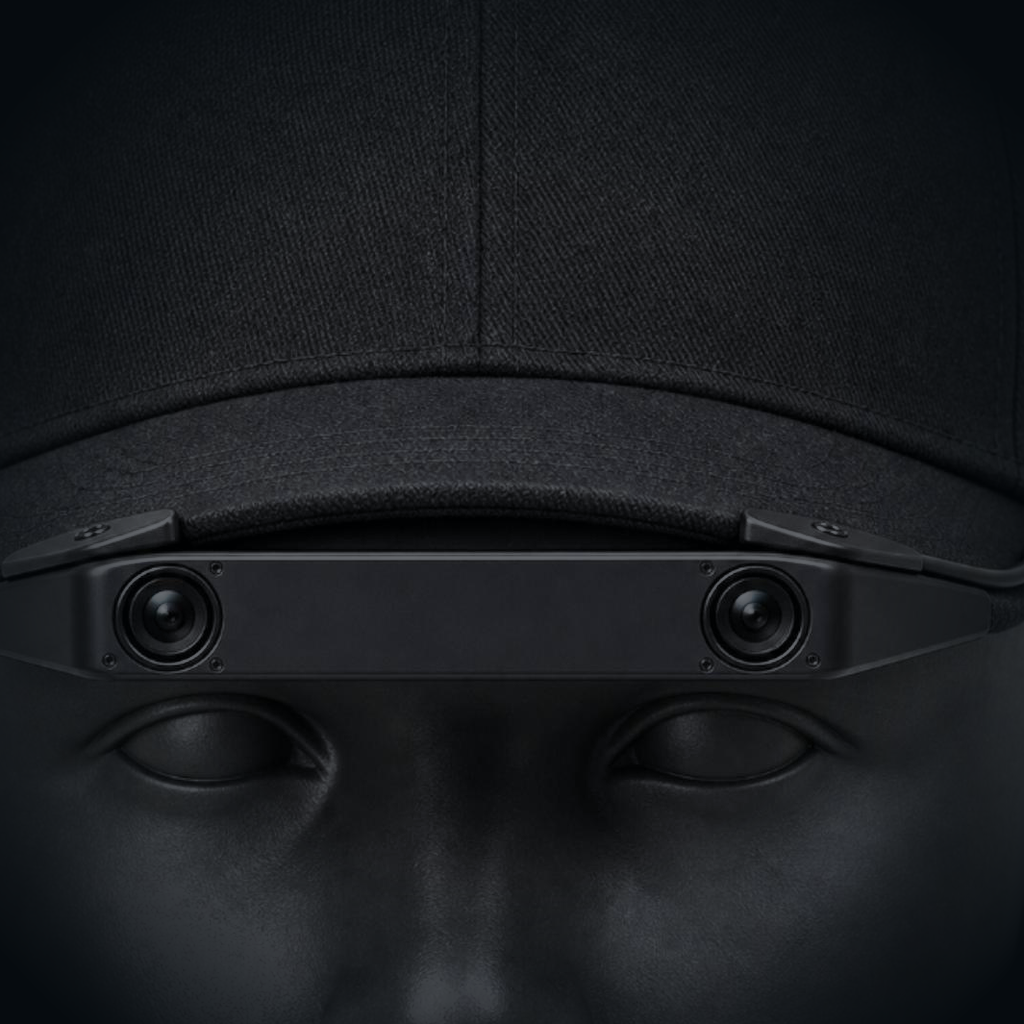
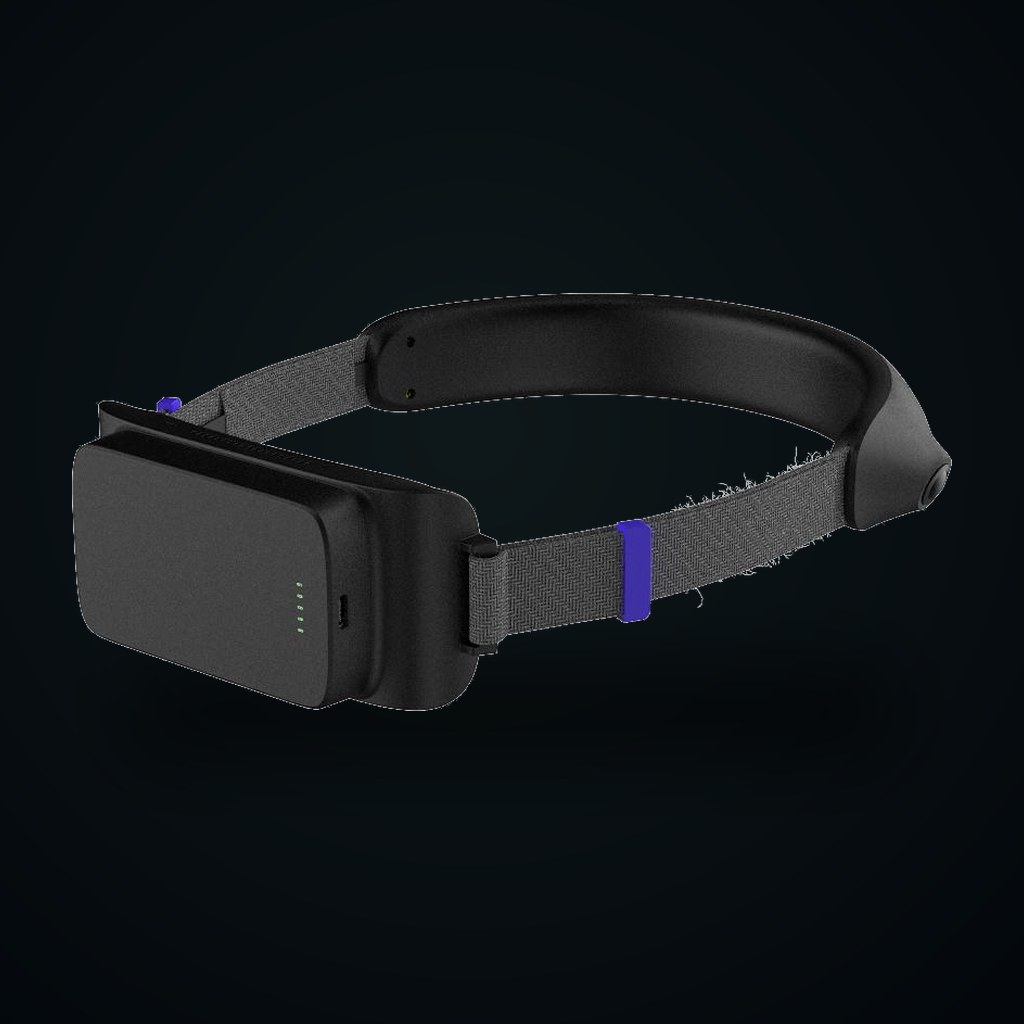
| Wego2 | Wego4 | |
|---|---|---|
| Cameras | 2 × global shutter | 4 × global shutter |
| Resolution | 1920 × 1200 each | 1920 × 1200 each |
| Coverage | 155° (V) × 109° (H) | 270° (H) × 155° (V) surround |
| On-Device Compute | 0.5 TOPS (RV1103B) | 3 TOPS (RV1126B) |
| CPU | Cortex-A7 + RISC-V | Quad-core Cortex-A53 |
| IMU | ICM-42688 6-axis, 200 / 500 Hz | ICM-42688 6-axis, 200 / 500 Hz |
| Battery | 5600 mAh hot-swap + 500 mAh UPS | 5600 mAh hot-swap + 500 mAh UPS |
| Wireless | Wi-Fi 6 + BLE 5.4 | Wi-Fi 6 + BLE 5.4 |
| Form Factor | Glasses / cap-brim module | Head-worn or mobile platform |
| Best for | Volume collection at low cost per unit | Wide work zones, on-rig quality control |
| Price | $900 | $1,500 |
RobooPi P53 — four automotive cameras, one CUDA box
Where Spatial Hub aggregates a building's cameras, RobooPi rides on the machine. NVIDIA Orin Nano, four GMSL2 / FPD-Link inputs on coax, and hardware frame sync — for vehicles, AMRs and anything that moves.
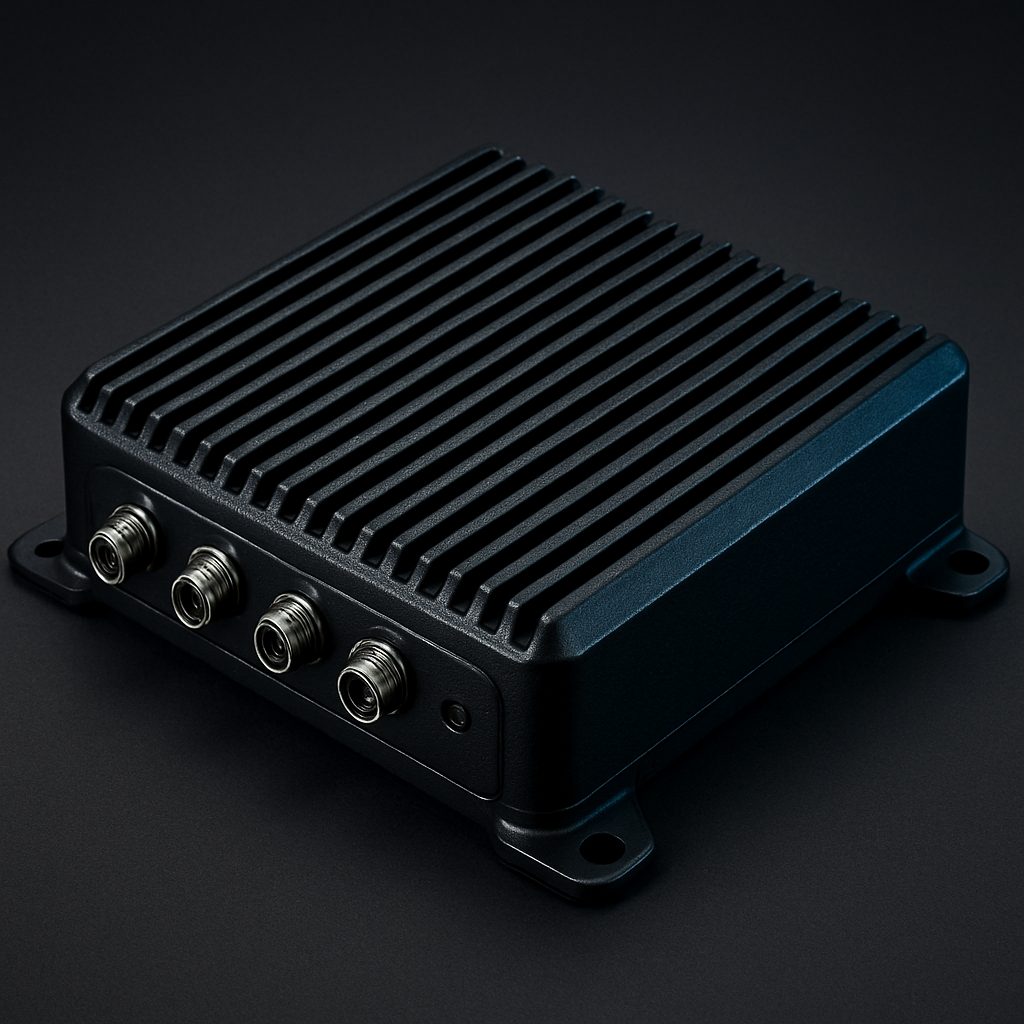
RobooPi P53
NVIDIA Orin Nano 8 GB with four Fakra GMSL2 camera inputs and hardware frame sync — built to ride on the machine.
40 TOPS, familiar stack
Orin Nano 8 GB on Ubuntu 20.04 — CUDA, TensorRT and the Jetson ecosystem your models already target.
One coax per camera
Fakra GMSL2 carries video, I²C control and 12 V PoC together. Optional FPD-Link deserialisers for existing camera stock.
Frames that line up
Hardware sync across devices and a single-channel lock output — multi-camera capture with timing you can trust.
Records as fast as it sees
128 GB on board, dual M.2 NVMe, and 2 channels of 1.2 GB/s local recording with an SSD fitted.
The platform outlives any single sensor
The VisionLibra stack is sensor-agnostic by design. As the lineup grows, your code doesn't change.
Spatial Hub — the brain of the fleet
Cameras sense. The Hub decides. Available now — runs the SpatialAI SDK and shipping models out of the box; NPU-accelerated marketplace models arrive via OTA.
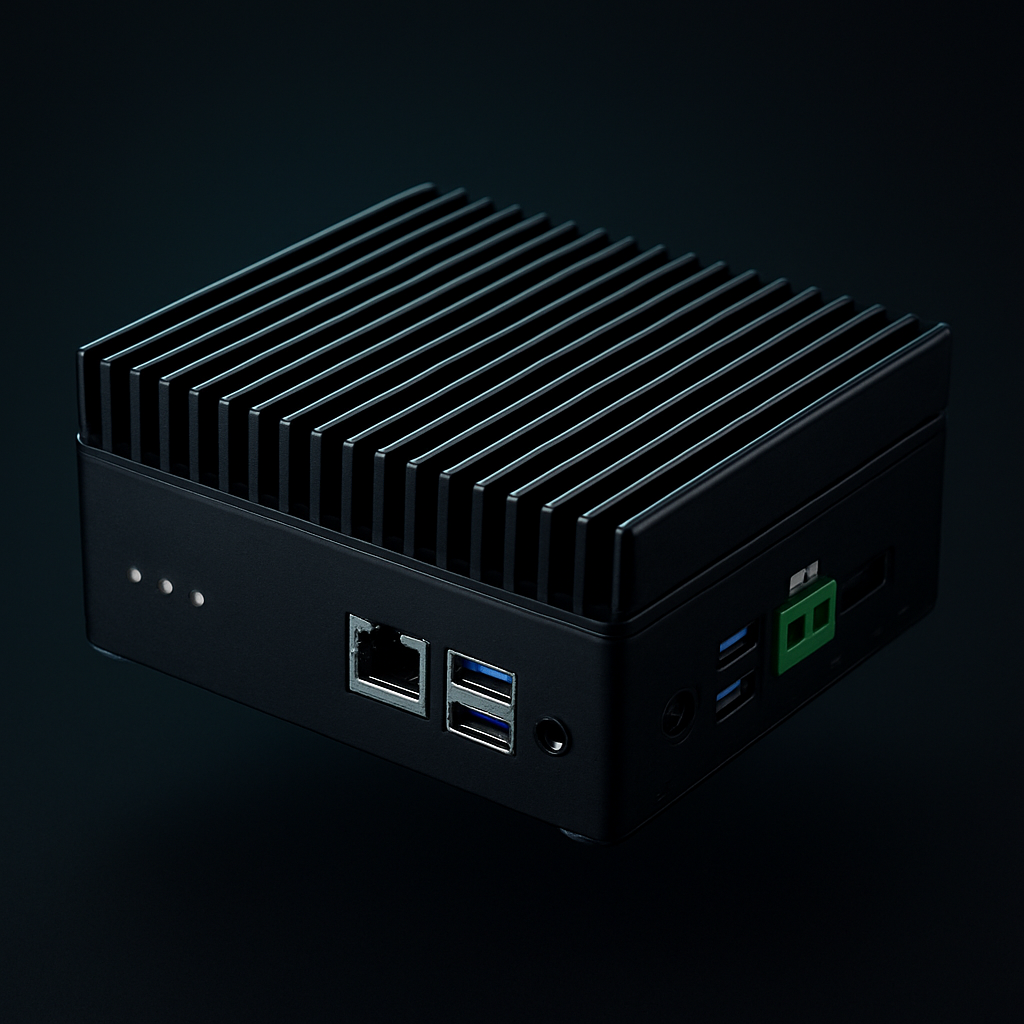
Spatial Hub
The compute node for your camera fleet. One fanless box ingests up to 32 camera streams and runs the SpatialAI runtime, models, and agents on-site — alerts, logs, and reports without a single frame leaving the building.
Every camera, one box
Ingests and decodes up to 32 concurrent streams — a full warehouse zone on a single Hub.
Models run on-site
The SpatialAI runtime executes marketplace models locally — deterministic latency, no cloud inference bill.
Agents act locally
Slack alerts, database records, and incident reports fire even when the uplink is down.
Privacy stays physical
Depth frames are processed and discarded on the box. Only events leave the building.